Nvidia's GR00T 2 learns robot skills from one human demo
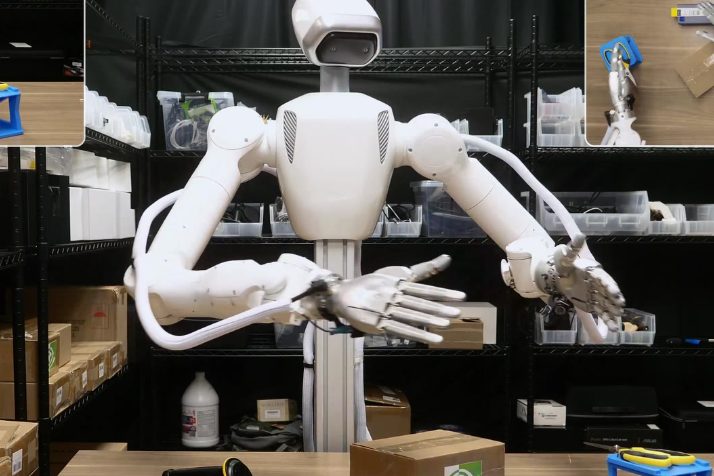
Nvidia unveiled GR00T 2, a robot model trained partly on 100,000 hours of human video
· Last verified: 10 Nov 2026 (Nvidia blog, DEV Community, CellCog)
Summary
- Nvidia unveiled GR00T 2, a robot model trained partly on 100,000 hours of human video
- Nvidia says one demo per task lifted success to 71%, five demos to 95%
- A single human demonstration could replace hundreds of robot demos on factory floors
The latest
A robot foundation model that learns tasks from human video rather than robot demonstrations is Nvidia's central claim for GR00T 2, announced November 9, 2026 at the CoRL robot learning conference in Austin, Texas. The company also released Isaac Lab 3.0, its open-source robot learning framework. Nvidia says GR00T 2 transfers skills across different robot bodies without robot demonstrations.
Details
- The model: GR00T 2 is an open world action model built on NVIDIA Cosmos, according to Nvidia. It was trained on a mix of robot data and human data, including 100,000 hours of open-source human egocentric video released by Nvidia. Its API lets AI agents chain skills and recover from errors mid-task.
- The numbers: Across 50 tasks, Nvidia reported the model completed 40 at least once with no task-specific demonstration. With a single demonstration per task, average success reached 71%. With five demonstrations per task, it reached 95%.
- Benchmark standing: Nvidia says GR00T 2 ranks in the top three in both the vision-language-action and world action model categories on the RoboCasa365, RoboLab, RoboDojo and MolmoSpaces benchmarks. Independent verification of those rankings was not part of the announcement.
- Isaac Lab 3.0: The framework integrates more tightly with the open-source Newton physics engine, simulating cables, cloth and articulated systems such as multi-jointed hands. Nvidia says training throughput reaches up to 2.5 times that of Isaac Lab 2.3 with PhysX on a vision-based manipulation benchmark, supporting thousands of simulated robots in parallel.
- Agent tooling: The release lets agents set up training environments using simulation-ready assets and switch between the PhysX and Newton engines. It adds a reinforcement learning post-training library for models including GR00T.
- AlphaNIST: Built in Isaac Lab, AlphaNIST is a single policy executing all 20 tasks on the NIST assembly task board. Nvidia reported training success above 98%, against 81% for separate per-task policies, using roughly 39 times less GPU time.
- New benchmarks: Nvidia introduced DexBench with RLWRLD, covering 15 tasks across retail, logistics, manufacturing and hospitality, and VABAR with the University of California, Berkeley, covering six industrial tasks. Both feed into Isaac Lab-Arena 0.4, arriving as a developer preview.
- Early users and partners: Nvidia named Nexuni for robotic laundry handling, Foxconn for server manufacturing automation, Siemens for evaluating industrial use cases, and MicroAGI for swapping Ethernet cables with a YAM arm. Partners cited include Skild AI, which announced a STEEL engine built on Newton, plus Flexion, FieldAI, Dyna Robotics, Walden Robotics and the University of Washington.
- Open questions: Nvidia describes GR00T 2 as an open model but did not state its parameter count, when the weights become available, or under what license. Its GRAIL and RoboTTT papers are among six best-paper finalists at CoRL.
Background
Robot learning has historically been bottlenecked by data: teaching a new task typically required hundreds of teleoperated robot demonstrations, each costly to collect. Human video is far more abundant, which is why transferring skills from it across different robot bodies is the headline claim here.
Between the lines
The 71% figure for one demonstration matters more commercially than the 95% figure for five. A warehouse or factory can plausibly record one human performing a task; recording five consistent demonstrations across hundreds of tasks is a different cost structure. The withheld parameter count, weight availability and license leave the practical meaning of open undefined for now.
What's next
Watch for the Isaac Lab-Arena 0.4 developer preview, the release of GR00T 2 weights and its license terms, CoRL best-paper results covering Nvidia's GRAIL and RoboTTT entries, and whether Foxconn or Siemens move beyond evaluation to deployment.